JetScan
By Shank
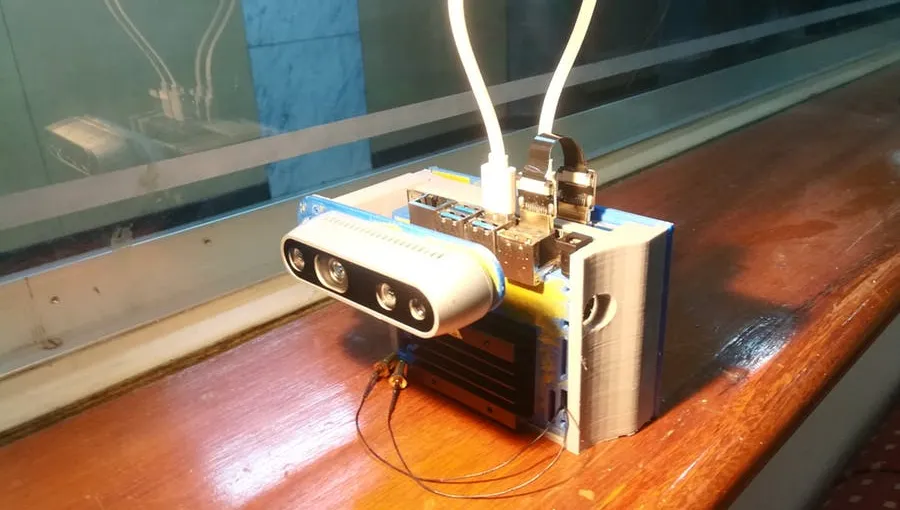
I stumbled on Open3D in the early 2020s. I already had an NVIDIA Jetson Nano and an Intel RealSense D435i sitting around, and pretty quickly I wanted a handheld 3D scanner in the same spirit as the Artec Leo — something that could capture on the device, reconstruct on the device, and leave you with a dense model without a workstation.
I did not know much about 3D reconstruction math or the pipeline at the time. I did know the project would teach me a lot.
I started by running Open3D on my laptop. The machine had a decent GPU, enough to try the CUDA reconstruction flow on public datasets before I touched the Jetson. After that, with only a rough sense of how to keep a software project together and a hardware lab that had a 3D printer, I started building.
JetScan was that build: Jetson Nano plus a RealSense D400-series camera, meant as a cheaper on-the-go scanner for people, objects, and environments, online or offline. NVIDIA later listed it on Jetson Projects.
I built it during my grad days. Looking back, the system design was not the most effective answer to the problem it was trying to solve. I still learned a great deal, including from strangers on the internet who took the time to help.
The project is abandoned now.
Stack
- NVIDIA Jetson Nano for onboard CUDA
- Intel RealSense D435i RGB-D capture
- Open3D (Intel ISL) plus theNded’s CUDA pipeline
- Software fork: Open3D-for-Jetson
Around the compute module I added a small display, Wi-Fi, a battery pack, and a 3D-printed enclosure. Assembly notes are on Hackster and in the hardware READMEs.
How it worked
- Capture RGB-D — Librealsense and OpenCV recorded an aligned color/depth sequence.
- Make fragments — GPU CUDA code split the sequence, ran RGB-D odometry, and integrated TSDF submaps.
- Register & refine — Adjacent submaps were registered, then refined with multi-scale colored ICP and a global pose.
- Integrate the scene — Optimized poses fused the full RGB-D stream into one reconstruction.
- View — The on-device UI (
Main_gui.py) showed the latest model: Capture → Reconstruct → View.
The CUDA path was much faster than the CPU-only Open3D baseline I had tried first.
Featured on NVIDIA
The official Jetson Projects listing is recapped below. Use Open on NVIDIA for the original page.
JetScan on NVIDIA Jetson Projects
Open on NVIDIANVIDIA Jetson Projects
JetScan
A smart, fast and metrically accurate GPU-accelerated 3D scanner with Jetson Nano and Intel depth sensor for instant 3D reconstruction. This system design makes on-the-go 3D scanning modules without external computing power affordable by any creator/maker around the world, giving users HD 3D models of scanned objects or environments instantly. Using RGBD stereo mapping, render 3D models of people, objects and environments with JetScan.
- Author
- S Hariharan K
- Works with
- Jetson Nano